hightorque
HTDW-7535-02-CNE Planetary Joint Module with Cross Roller Bearing – 35:1, 20Nm, 70Nm Peak, CANFD/CAN
HTDW-7535-02-CNE Planetary Joint Module with Cross Roller Bearing – 35:1, 20Nm, 70Nm Peak, CANFD/CAN
Couldn't load pickup availability
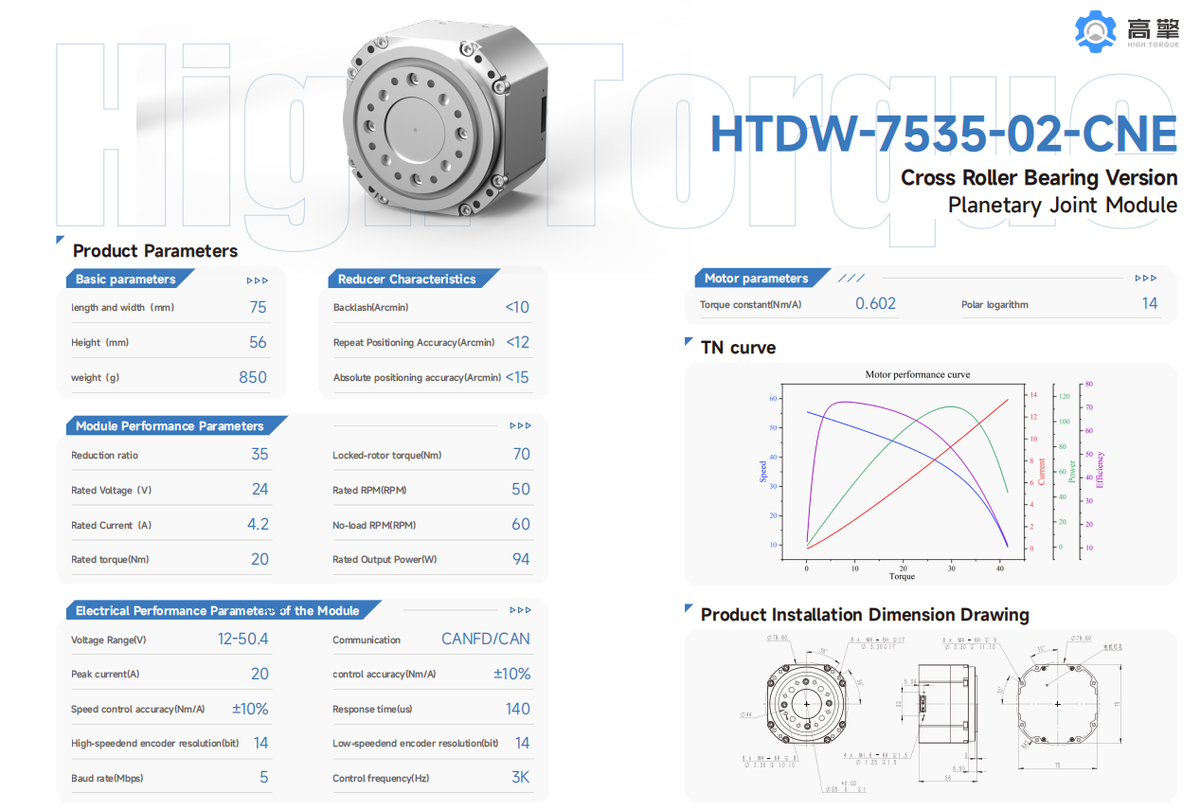
The HTDW-7535-02-CNE is a heavy-torque planetary joint module with a cross roller bearing output, engineered for large robotic arms, legged robots, and high-load automation joints. At 75 × 56 mm and 850 g, it delivers 20 Nm rated torque and 70 Nm locked-rotor torque through a 35:1 planetary reduction, with dual 14-bit encoders for closed-loop position, velocity, and current control.
Key Features:
- Cross roller bearing output – high radial/axial stiffness and moment rigidity for demanding joint applications.
- Planetary gear reducer – 35:1 reduction, high drive efficiency in a compact body.
- 20 Nm rated / 70 Nm locked-rotor torque – the highest torque in the HTDW lineup.
- Self-designed brushless DC motor – low cogging torque and low torque ripple.
- Dual 14-bit absolute encoders – accurate position and torque feedback for closed-loop control.
- CANFD / CAN communication – 5 Mbps baud rate, easy integration with existing robot control architectures.
- Wide voltage range – 12–50.4 V DC input, 24 V rated.
Specifications:
Model: HTDW-7535-02-CNE
Series: HTDW Series Planetary Joint Module (Cross Roller Bearing Version)
Outline: 75 × 75 × 56 mm (length and width × height)
Weight: 850 g
Reduction Ratio: 35:1
Rated Voltage: 24 V DC
Voltage Range: 12–50.4 V DC
Rated Current: 4.2 A
Peak Current: 20 A
Rated Torque: 20 Nm
Locked-Rotor Torque: 70 Nm
Rated Speed: 50 RPM
No-Load Speed: 60 RPM
Rated Output Power: 94 W
Torque Constant: 0.602 Nm/A
Backlash: under 10 arcmin
Repeat Positioning Accuracy: under 12 arcmin
Absolute Positioning Accuracy: under 15 arcmin
Encoder Resolution: 14 bit (dual, high-speed and low-speed ends)
Communication: CANFD / CAN
Baud Rate: 5 Mbps
Control Frequency: 3 kHz
Response Time: 140 μs
Pole Pairs: 14
Control Accuracy: ±10%
Applications: Large robotic arms, humanoid robots, legged robots, AGVs, aerospace actuators, medical/rehabilitation equipment, precision automation
Applications:
Designed for large robotic arm joints, humanoid robots, legged robots, automated guided vehicles (AGVs), aerospace actuators, medical/rehabilitation equipment, and precision automation systems. The cross roller bearing output supports high moment loads, making it ideal for shoulder, hip, and knee joints that carry the heaviest loads.
What's in the Box:
- 1 × HTDW-7535-02-CNE planetary joint module
- Mounting screws and hardware (as per SKU configuration)
Looking for a different reduction ratio, output bearing type, or communication interface? Contact us for customization and OEM/ODM options.
Share