hightorque
HTDW-6036-02-CNE Planetary Joint Module with Cross Roller Bearing – 36:1, 10Nm, 45Nm Peak, CANFD/CAN
HTDW-6036-02-CNE Planetary Joint Module with Cross Roller Bearing – 36:1, 10Nm, 45Nm Peak, CANFD/CAN
Couldn't load pickup availability
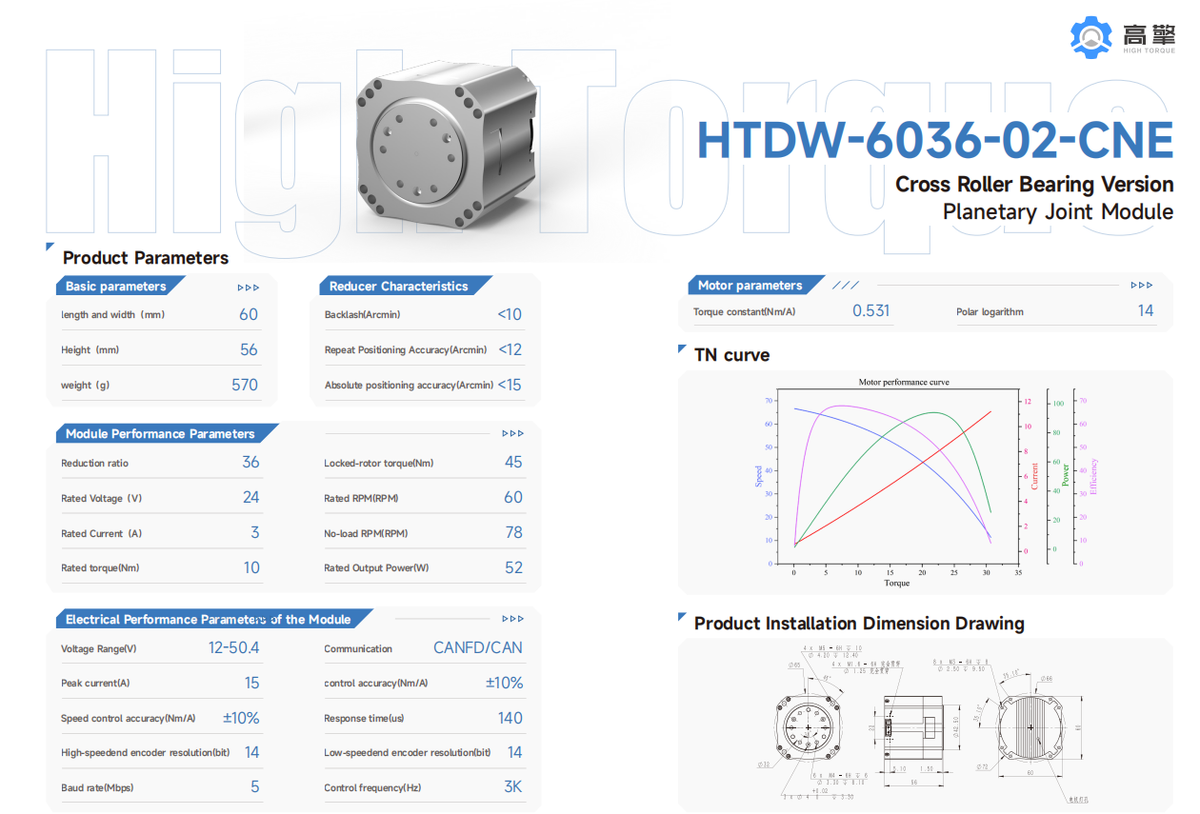
The HTDW-6036-02-CNE is a high-torque planetary joint module with a cross roller bearing output, engineered for compact robotic arms, exoskeletons, and precision automation joints. At 60 × 56 mm and 570 g, it delivers 10 Nm rated torque and 45 Nm locked-rotor torque through a 36:1 planetary reduction, with dual 14-bit encoders for closed-loop position, velocity, and current control.
Key Features:
- Cross roller bearing output – high radial/axial stiffness and moment rigidity for demanding joint applications.
- Planetary gear reducer – 36:1 reduction, high drive efficiency in a compact body.
- 10 Nm rated / 45 Nm locked-rotor torque – strong output for shoulder, elbow, and wrist joints.
- Self-designed brushless DC motor – low cogging torque and low torque ripple.
- Dual 14-bit absolute encoders – accurate position and torque feedback for closed-loop control.
- CANFD / CAN communication – 5 Mbps baud rate, easy integration with existing robot control architectures.
- Wide voltage range – 12–50.4 V DC input, 24 V rated.
Specifications:
Model: HTDW-6036-02-CNE
Series: HTDW Series Planetary Joint Module (Cross Roller Bearing Version)
Outline: 60 × 60 × 56 mm (length and width × height)
Weight: 570 g
Reduction Ratio: 36:1
Rated Voltage: 24 V DC
Voltage Range: 12–50.4 V DC
Rated Current: 3 A
Peak Current: 15 A
Rated Torque: 10 Nm
Locked-Rotor Torque: 45 Nm
Rated Speed: 60 RPM
No-Load Speed: 78 RPM
Rated Output Power: 52 W
Torque Constant: 0.531 Nm/A
Backlash: under 10 arcmin
Repeat Positioning Accuracy: under 12 arcmin
Absolute Positioning Accuracy: under 15 arcmin
Encoder Resolution: 14 bit (dual, high-speed and low-speed ends)
Communication: CANFD / CAN
Baud Rate: 5 Mbps
Control Frequency: 3 kHz
Response Time: 140 μs
Pole Pairs: 14
Control Accuracy: ±10%
Applications: Robotic arms, humanoid robots, exoskeletons, AGVs, aerospace actuators, medical/rehabilitation equipment, precision automation
Applications:
Designed for robotic arm joints, humanoid robots, exoskeletons, automated guided vehicles (AGVs), aerospace actuators, medical/rehabilitation equipment, and precision automation systems. The cross roller bearing output supports high moment loads, making it ideal for shoulder, elbow, and wrist joints.
What's in the Box:
- 1 × HTDW-6036-02-CNE planetary joint module
- Mounting screws and hardware (as per SKU configuration)
Looking for a different reduction ratio, output bearing type, or communication interface? Contact us for customization and OEM/ODM options.
Share