hightorque
HTDW-5022-02-DNE Planetary Joint Module – 22:1, 3.5Nm, 13Nm Peak, CANFD/CAN
HTDW-5022-02-DNE Planetary Joint Module – 22:1, 3.5Nm, 13Nm Peak, CANFD/CAN
Couldn't load pickup availability
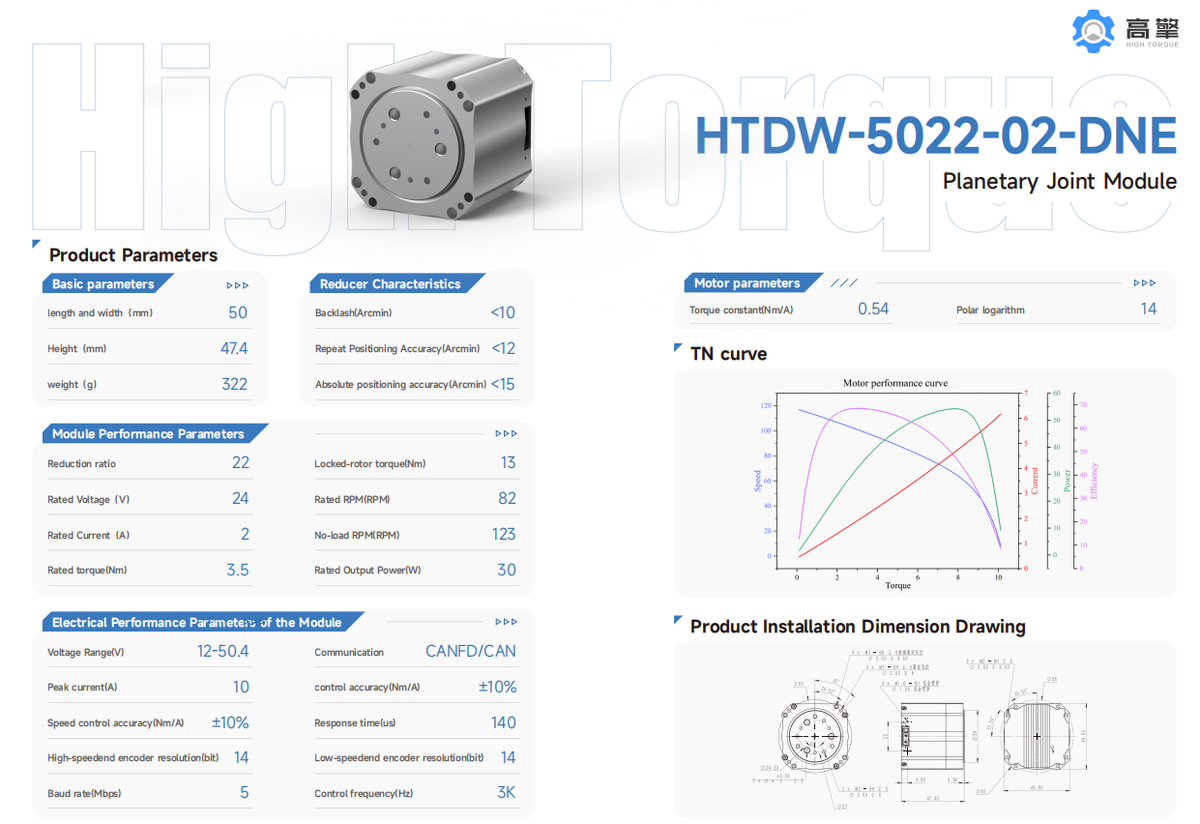
The HTDW-5022-02-DNE is a compact planetary joint module engineered for lightweight robotic arms, exoskeletons, and precision automation joints. At just 50 × 47.4 mm and 322 g, it delivers 3.5 Nm rated torque and 13 Nm locked-rotor torque through a 22:1 planetary reduction, with dual 14-bit encoders for closed-loop position, velocity, and current control.
Key Features:
- Planetary gear reducer – 22:1 reduction, high drive efficiency in a compact 50 mm body.
- 3.5 Nm rated / 13 Nm locked-rotor torque – solid output for lightweight joints.
- Self-designed brushless DC motor – low cogging torque and low torque ripple.
- Dual 14-bit absolute encoders – accurate position and torque feedback for closed-loop control.
- CANFD / CAN communication – 5 Mbps baud rate, easy integration with existing robot control architectures.
- Wide voltage range – 12–50.4 V DC input, 24 V rated.
- Lightweight – only 322 g, ideal for weight-sensitive multi-joint robots.
Specifications:
Model: HTDW-5022-02-DNE
Series: HTDW Series Planetary Joint Module
Outline: 50 × 50 × 47.4 mm (length and width × height)
Weight: 322 g
Reduction Ratio: 22:1
Rated Voltage: 24 V DC
Voltage Range: 12–50.4 V DC
Rated Current: 2 A
Peak Current: 10 A
Rated Torque: 3.5 Nm
Locked-Rotor Torque: 13 Nm
Rated Speed: 82 RPM
No-Load Speed: 123 RPM
Rated Output Power: 30 W
Torque Constant: 0.54 Nm/A
Backlash: under 10 arcmin
Repeat Positioning Accuracy: under 12 arcmin
Absolute Positioning Accuracy: under 15 arcmin
Encoder Resolution: 14 bit (dual, high-speed and low-speed ends)
Communication: CANFD / CAN
Baud Rate: 5 Mbps
Control Frequency: 3 kHz
Response Time: 140 μs
Pole Pairs: 14
Control Accuracy: ±10%
Applications: Robotic arms, humanoid robots, exoskeletons, AGVs, aerospace actuators, medical/rehabilitation equipment, precision automation
Applications:
Designed for robotic arm joints, humanoid robots, exoskeletons, automated guided vehicles (AGVs), aerospace actuators, medical/rehabilitation equipment, and precision automation systems. The compact size and light weight make it especially suitable for wrist joints and multi-degree-of-freedom arms where every gram counts.
What's in the Box:
- 1 × HTDW-5022-02-DNE planetary joint module
- Mounting screws and hardware (as per SKU configuration)
Looking for a different reduction ratio, output bearing type, or communication interface? Contact us for customization and OEM/ODM options.
Share